
Introduction — A Garage Moment, Some Numbers, and a Question
I was under a workbench once, wire cutters in my teeth, trying to quiet a jittery motor—classic Tuesday, right? In that little mess I kept thinking about field failures and surprising downtime numbers: manufacturers report as much as 20–30% of motor-related service calls tied to control issues. A motor controller sat squarely in the second sentence of that thought, the quiet ingredient that either makes a system sing or sends it to the shop. (You know the type — small board, big attitude.)
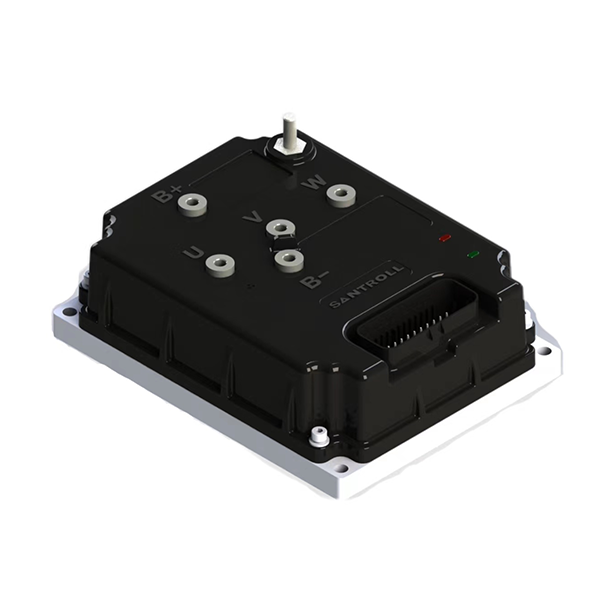
Here’s the punch: most teams I meet focus on raw power or cheap parts, not on how the controller talks to the motor. So I ask: are we fixing the right thing, or just treating symptoms? I’ll walk through a real-world setup, call out where solutions fail, and point to sensible tactics you can use tomorrow. Let’s move from the grease-stained bench to the why and how—next up, the common faults that trip up motor control solutions. — stick with me.
Digging Deeper: Why Common Motor Control Solutions Often Fall Short
What’s really broken?
First, let me define the problem plainly: motor control solutions are supposed to manage torque, speed, and efficiency, but many designs miss the mark because they treat the controller like a commodity. I’ve seen systems that rely on crude PWM timing or mismatched power converters and then wonder why the motor hums, skips, or consumes too much energy. Field-oriented control, when done poorly, turns into a band-aid rather than a design advantage.
Technically speaking, the issues cluster around three things: sensing errors (bad feedback or none at all), control loop tuning that never made it past lab settings, and overload of legacy components that weren’t designed for sensorless control. Look, it’s simpler than you think: when sensor signals lag or noise creeps in, the control loop reacts late, producing torque ripple and wear. I’ve debugged systems where a marginal current-sense resistor was the culprit—funny how that works, right? The result is higher maintenance, more downtime, and unhappy operators.
Fixes and Forward View: Principles for Better Controllers
What’s Next?
Now let’s be practical. I prefer to frame improvements around principles, not buzzwords. Start with robust sensing and diagnostic channels. Add modest processing headroom so the controller can run a decent observer or adaptive filter without sweating. For many mid-range drives, the shift from clunky open-loop designs to true closed-loop control (even sensorless) yields the best uptime gains. And yes—consider edge computing nodes for local diagnostics if you have distributed systems; it’s not snake oil, it’s practical telemetry.
For brushless designs specifically, the bldc motor controller you choose should support real-time diagnostics, clean PWM drive stages, and easy firmware updates. In practice, that means looking for controllers that expose current and voltage readings, let you tweak PID or FOC parameters, and log faults. I’d also push for firmware that can be tuned offline then rolled out — saves time on the floor. — small step, big return.
Let me leave you with three concrete metrics I use when evaluating controllers: 1) Control accuracy under load (steady-state speed error), 2) Fault detection responsiveness (ms range), and 3) Thermal margin at peak torque. These tell you how well a controller will behave in the real world, not just on paper. If a part checks those boxes, I give it a nod. If not, I keep searching. For practical options and parts I trust, I often start vetting with Santroll.