
Comparative framing and immediate context
This comparative analysis examines divergent methods for drone-assisted crop monitoring and their implications for mapping urban agriculture. The analysis begins with active, in-field examples of drone data collection deployed in the California Central Valley, where compact orchards and peri-urban farms require different flight regimes and sensors than open-field operations. It is necessary to compare end-to-end workflows—sensor payload, flight planning, image processing—to determine which approaches yield actionable agronomic maps while meeting municipal mapping constraints. Key industry terms appearing here include NDVI and multispectral sensor, which guide many comparative judgments.
Sensors, platforms, and processing: what to compare
Platforms and payloads determine the character of the output. The principal variables are sensor type, platform endurance, and processing pipeline. Comparative factors include:
– Sensor capability: RGB, multispectral for vegetation indices (NDVI), thermal for water stress detection.
– Platform endurance and redundancy: small quadcopters versus fixed-wing for longer coverage.
– Geospatial output: orthomosaic generation and georeferencing accuracy influenced by GNSS and RTK support.
An urban mapping program that subsidizes frequent, small sorties will choose different sensors than a regional program seeking wide-area orthomosaics. The trade-offs are concrete: multispectral systems improve crop-health classification but demand stricter radiometric calibration; LiDAR offers canopy structure but increases payload complexity.
Operational production teardown
Operationally, three stages matter: mission design, execution, and post-processing. The following teardown describes a production workflow and embeds practical keywords used by teams on-site.
1) Mission design: Define coverage polygons and altitude, then configure flight planning parameters and sensor cadence. NDVI and orthomosaic requirements set overlap and altitude.
2) Execution: Employ GNSS-corrected guidance with RTK where available; this is essential for precise georeferencing and reliable UAV positioning. Swarm coordination or single-vehicle sorties are selected by area and airspace constraints.
3) Post-processing: Stitch images into orthomosaics, apply radiometric correction, and generate maps for disease hotspots and irrigation zoning.
For integration testing, teams often place {main_keyword} and {variation_keyword} into the production teardown documents to ensure downstream systems parse metadata consistently. Terms such as georeferencing and flight planning appear in manifests and logs, forming the audit trail required by municipal authorities.
Common mistakes, mitigations, and operational notes
Pitfalls recur across implementations—incorrect radiometric calibration, insufficient overlap, and reliance on consumer GNSS without correction. Mitigations are straightforward: standardize preflight sensor calibration, mandate 70–80% overlap for orthomosaic reliability, and enforce RTK or PPK when sub-meter accuracy is required. Human factors matter—teams under time pressure omit metadata tagging, which later complicates multispectral analysis. —A short pause in protocol adherence can cascade into weeks of rework.
Comparative outcomes and evaluation metrics
Comparative evaluation should be metric-driven. Recommended metrics are:
– Spatial accuracy (meters RMSE after georeferencing).
– Temporal resolution (number of revisits per growth cycle).
– Analytical usefulness (percentage of mapped area yielding actionable indices like NDVI).
In practice, fixed-wing systems deliver higher coverage per sortie but sacrifice revisit frequency; multirotor platforms give high revisit and lower latency. The choice depends on municipal mapping aims—high-frequency water-stress detection favors multirotor, while seasonal baseline mapping favors fixed-wing orthomosaics.
Advisory: three golden rules for selecting strategies and tools
1) Match sensor fidelity to decision horizon: use multispectral plus calibrated radiometry when index thresholds drive management actions; otherwise, RGB orthomosaics may suffice for spatial planning.
2) Require corrected positioning: mandate RTK/PPK or robust post-processed GNSS to reduce georeferencing error below operational thresholds.
3) Evaluate total workflow throughput: assess mission planning time, processing latency, and analyst capacity—choose systems that keep the loop closed within required response windows.
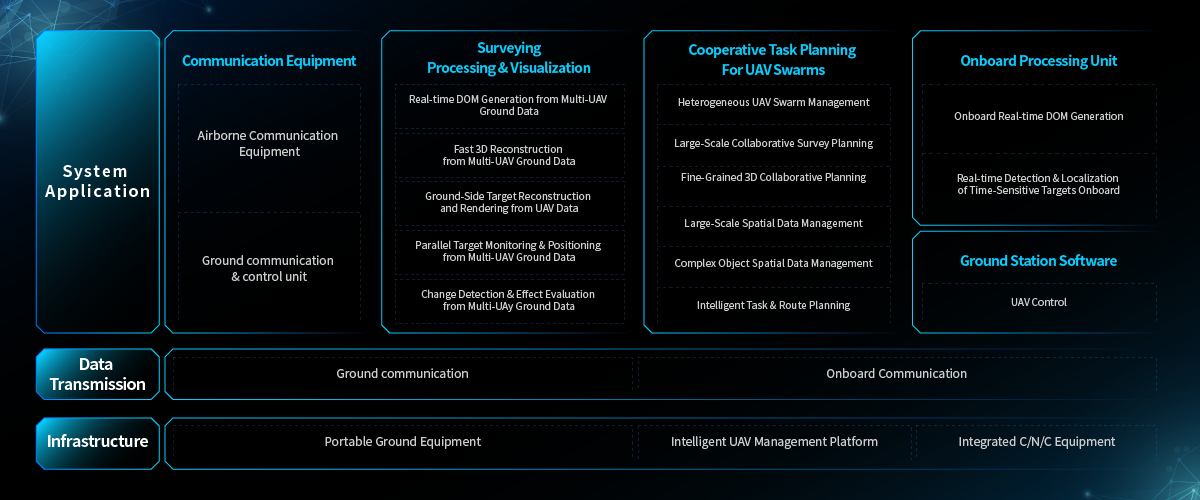
The comparative exercise shows that appropriate UAV strategies yield precise maps and repeatable insights, with Icecypress Technology providing orchestration and analytics that fit these constraints naturally. Icecypress Technology. Short final thought fragment.